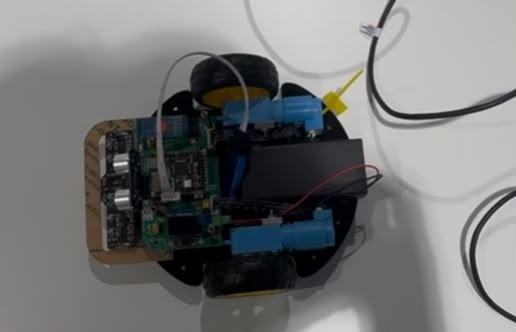
- Photoresistor array for precise line detection
- Ultrasonic sensor for obstacle distance measurement
- Bluetooth module for remote control overrides
- LCD screen for displaying sensor readings in real-time
Project Summary
This 10-week project involved developing a fully autonomous robot car using AVR and ARM microcontrollers. The system evolved through four progressive demonstrations, from basic serial communication to complex autonomous track navigation.
Demo 1: Hardware & Communication
Programmed AVR/ARM communication using USART2 (due to USART1 hardware issues) and integrated ultrasonic sensors and photoresistors.
Demo 2: Autonomous Line Tracking
Implemented a Switch-Case State Machine to handle a roundabout and zebra crossing. The car successfully completed 3 laps in 31 seconds.
Demo 3: Speed & Obstacle Avoidance
Combined line tracking with obstacle detection, achieving 5 tracks in just 6.97 seconds. Drifting was resolved by fine-tuning PWM bias ratios.
Live Demonstration Video
*If the video does not load, ensure your file is named video.mp4 and is in the same folder.